3D Object Detection
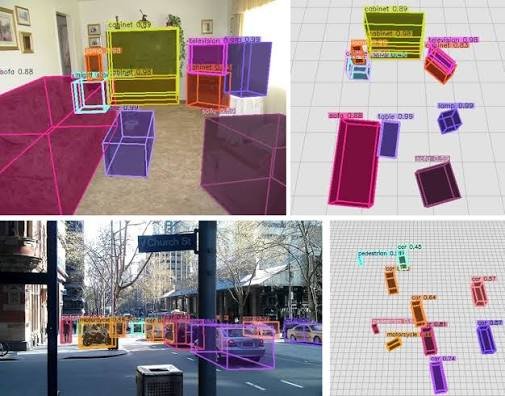
Highly accurate identification and localization of vehicles, pedestrians, cyclists, and critical infrastructure within 3D space.
Precise application of 3D bounding boxes that perfectly encapsulate targeted objects across all three dimensions (X, Y, Z).
Detailed annotation of object heading, orientation, pitch, yaw, and roll to predict movement direction and behavioral intent.
Specialized edge-case handling for occluded, truncated, or distant objects to ensure robust model performance in real-world scenarios.
Multi-sensor data fusion capabilities to perfectly cross-validate object detection between LiDAR point clouds and RGB camera imagery.